Gyro
A 9-axis motion sensor reporting roll, pitch, and heading — an expansion sensor for the FloorPro.
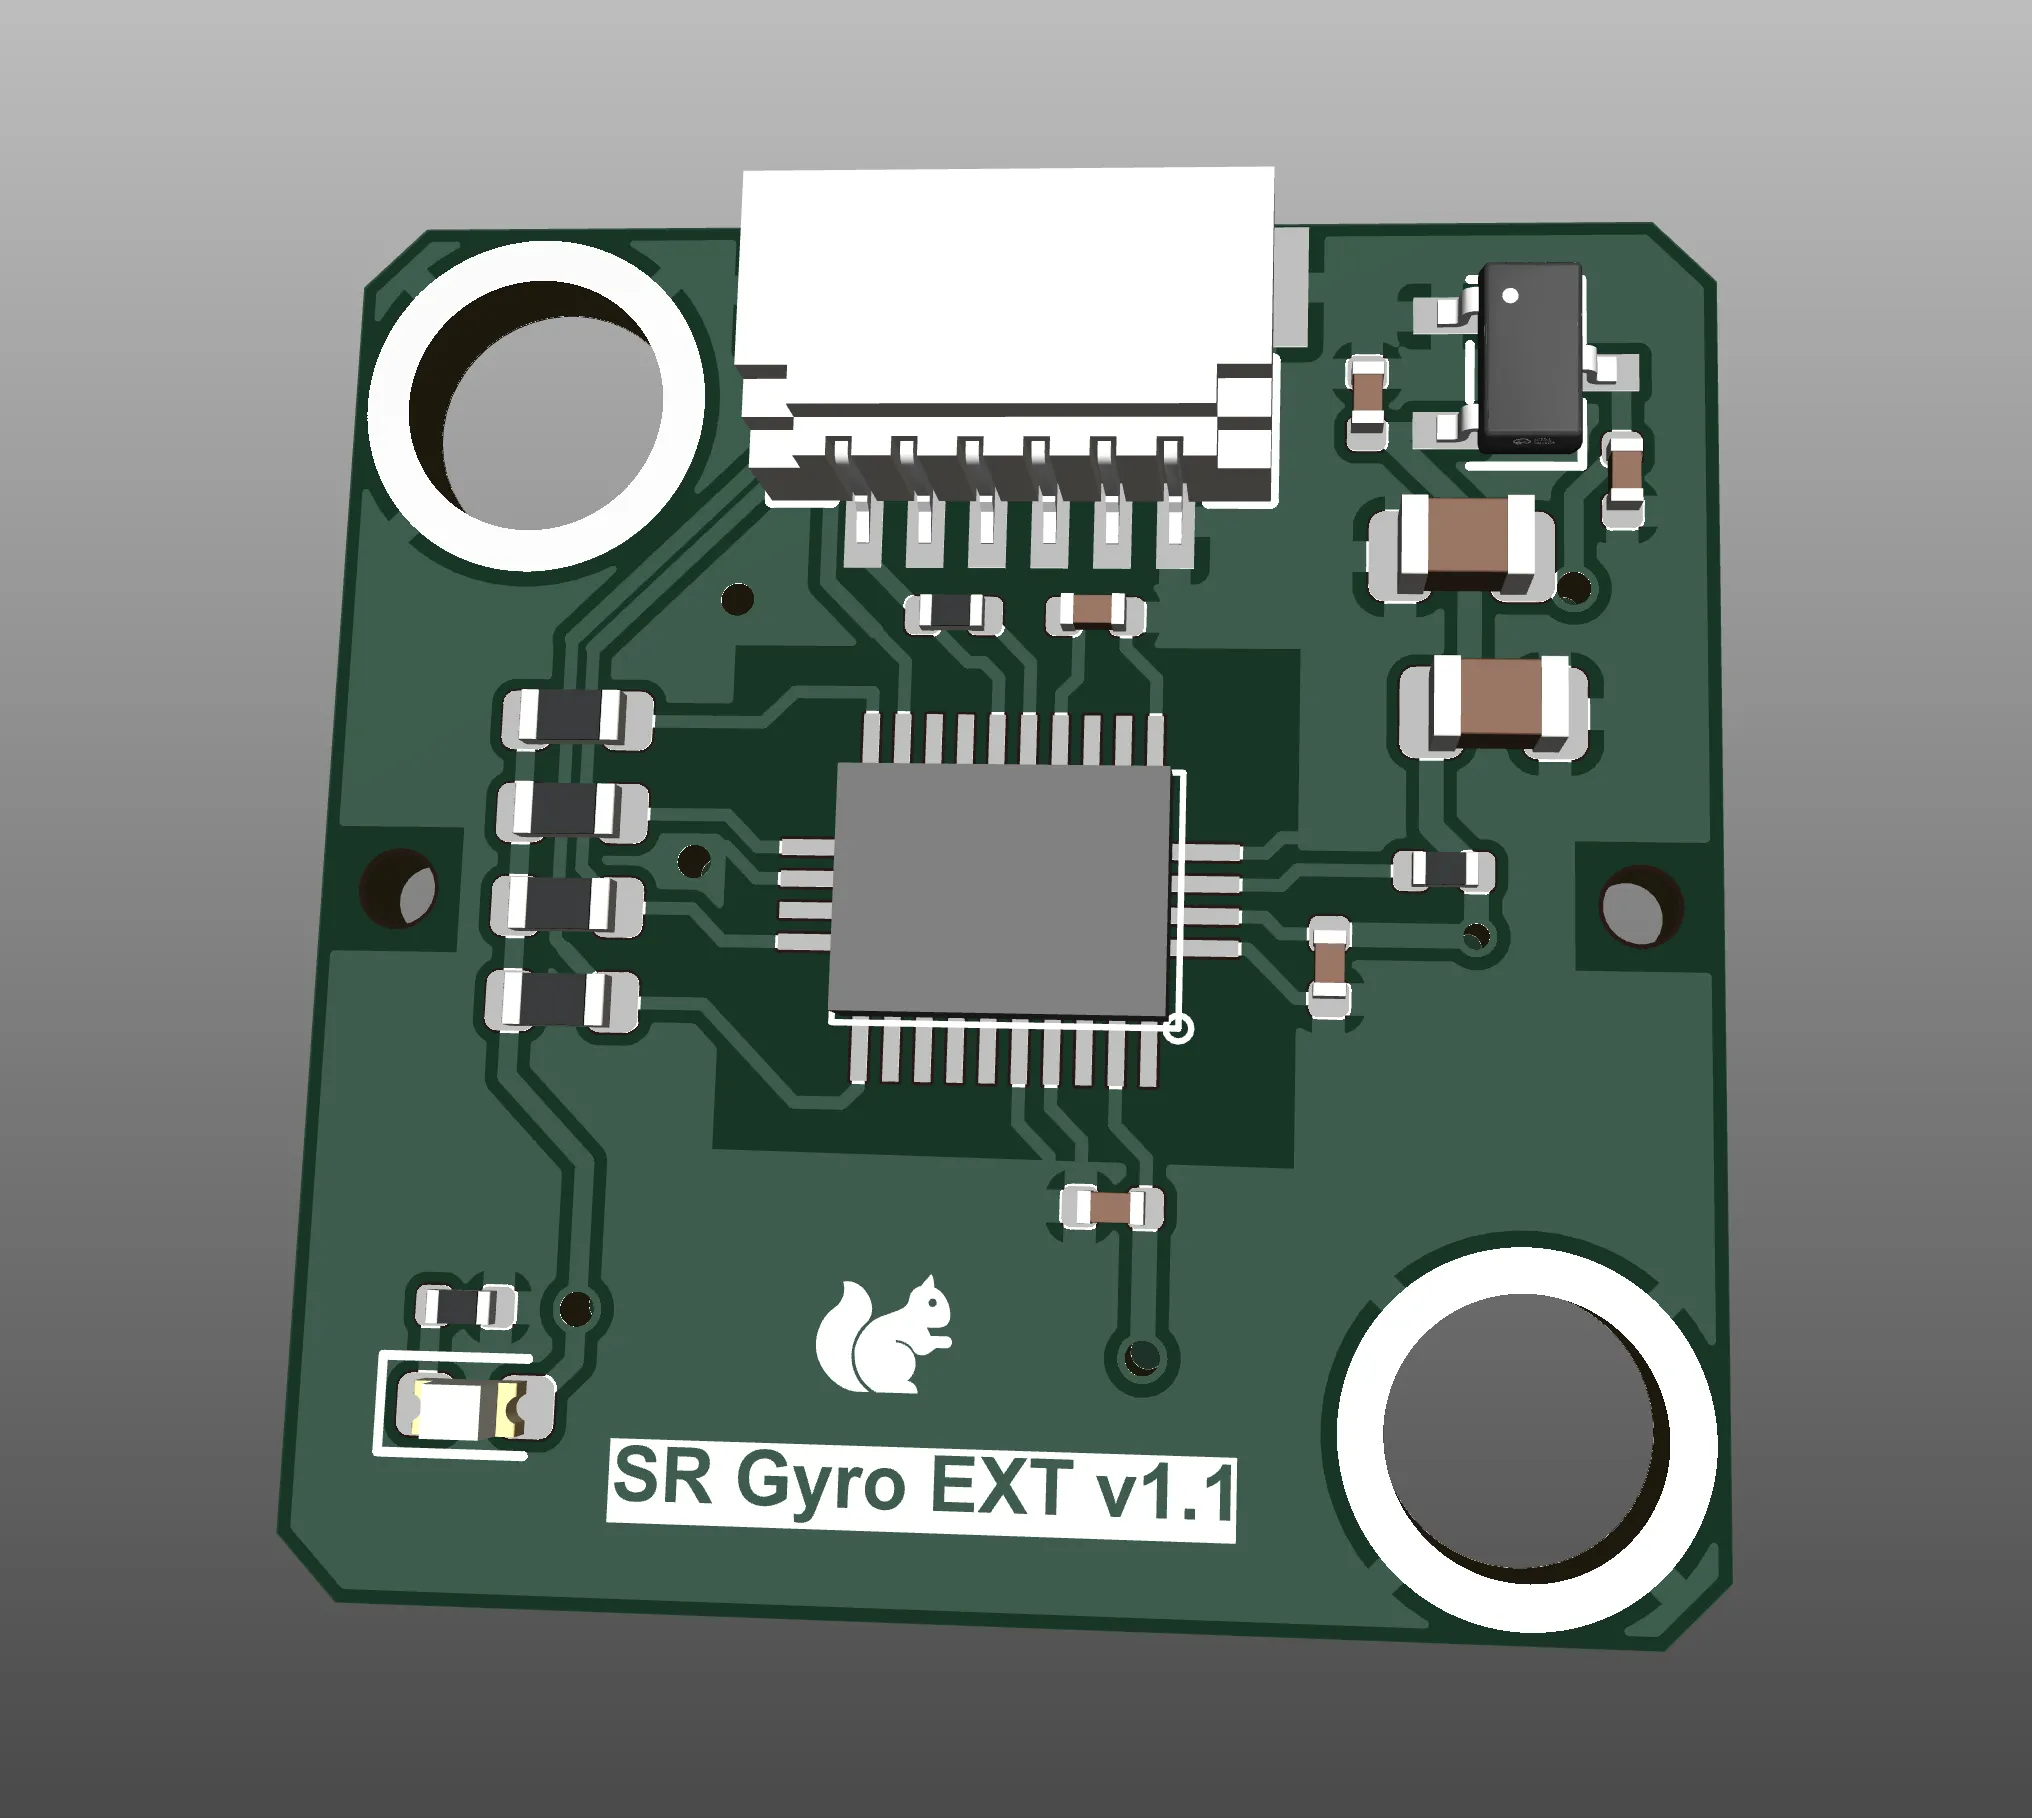
| Sensor | BNO086 9-axis IMU (accelerometer + gyroscope + magnetometer) |
|---|---|
| Output | Roll, pitch, and yaw (heading), fused in real time |
| Features | Automatic mounting-orientation detection, heading reset, persisted yaw-scale calibration |
| Connection | FloorPro expansion port (EXT1 or EXT2), auto-detected at power-up |
| Compatibility | PeakHub (PUMP) and LEGO Prime/Inventor hubs with Pybricks (LUMP) |
The Gyro gives your robot a sense of orientation. Built on a BNO086 9-axis IMU, it fuses accelerometer, gyroscope, and magnetometer data on-device and reports roll, pitch, and yaw (heading) in real time — no drift-prone raw integration required.
An expansion sensor for FloorPro
The Gyro plugs into either expansion port on the FloorPro — EXT1 or EXT2 — and is detected automatically at power-up. Pair it with a Color Sensor on the other port; every combination works.
Accurate heading, made easy
- Auto-orientation: mounting orientation is detected at start-up, so heading is always measured around true vertical.
- Heading reset: zero the heading at any time from your program.
- Yaw-scale calibration: correct per-revolution scale error once; the result is stored and applied on every boot.
What you can build
- Precise turns and headings for navigation.
- Self-balancing and tilt-reactive builds.
- Compass-style behaviors where clockwise rotation increases the heading.
Code examples
Ready-to-run demos are on GitHub: Gyro-CodeDemos.